
-
Leon Zhang Sales Manager
-
Email: sale@relayprotect.com
-
Phone/WhatsApp: +86 13655813266
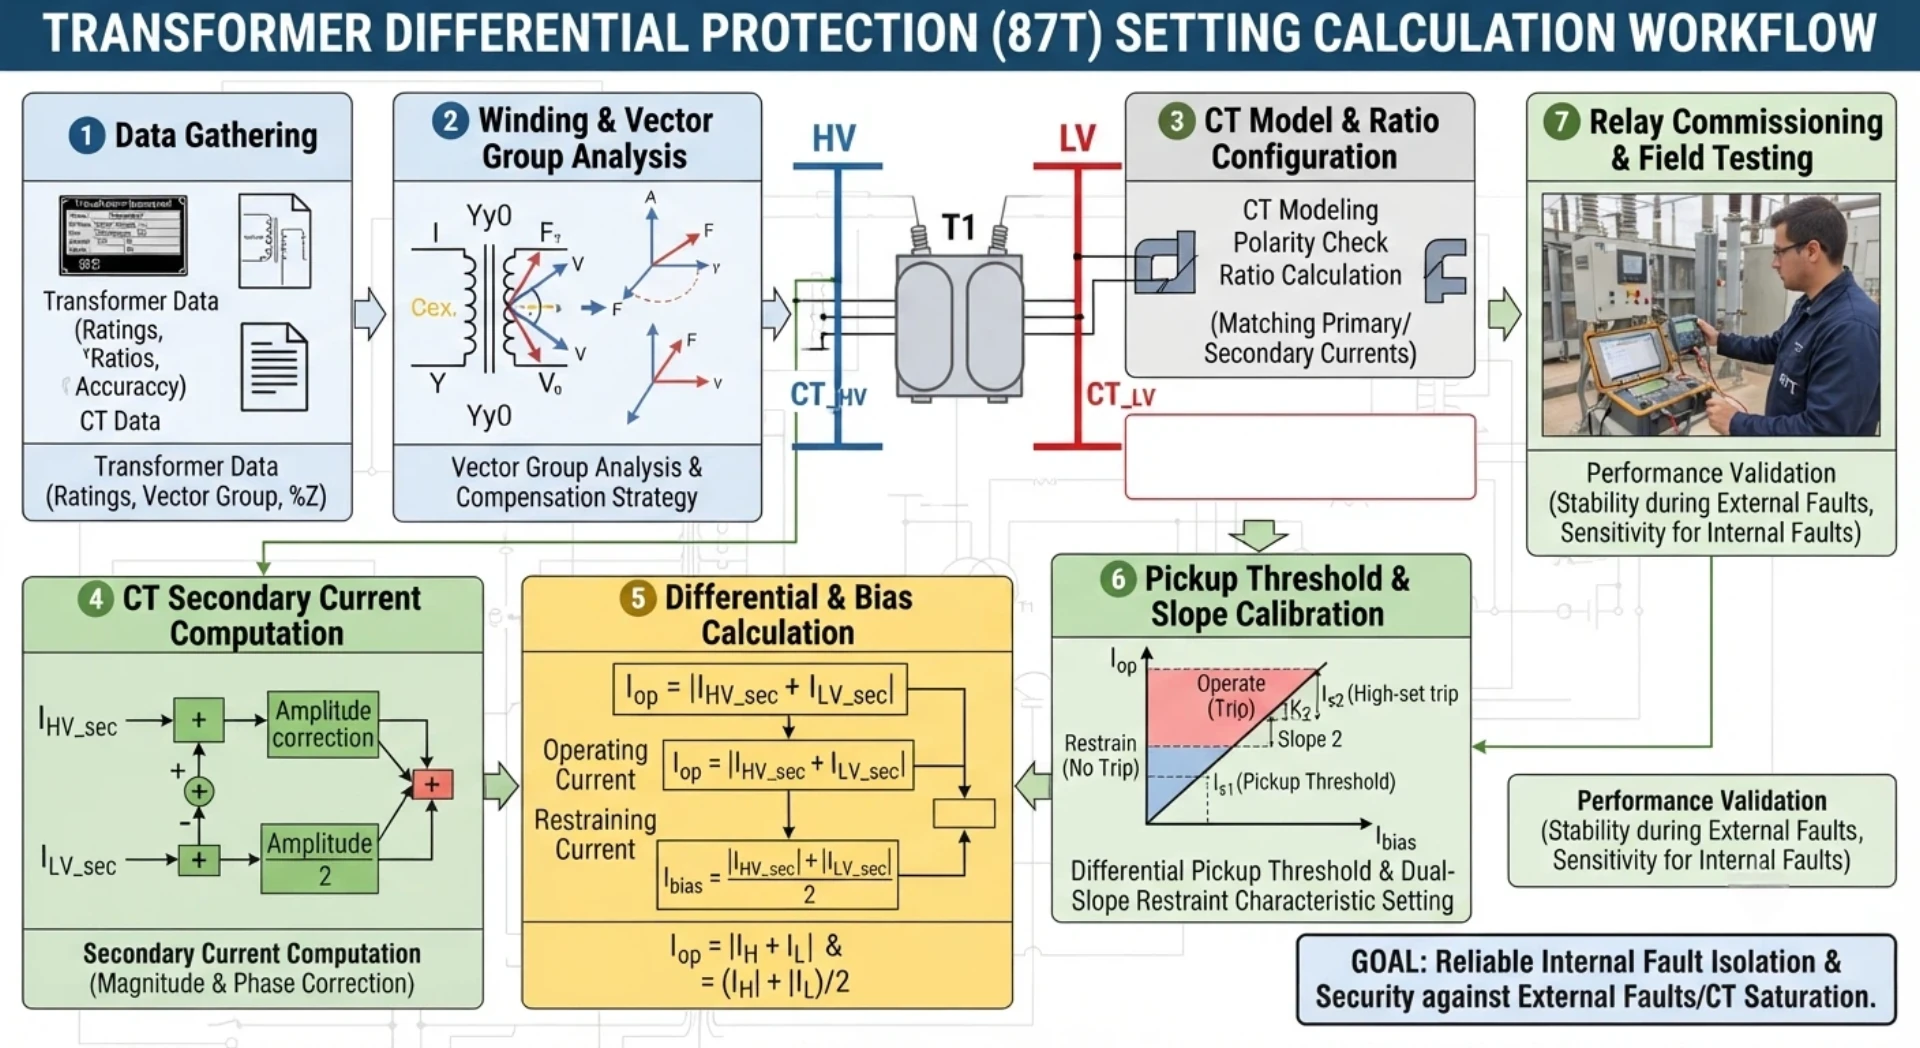
Differential Protection Setting Calculation: Pickup, Slope and Stability Formulas
What four numbers does a differential protection setting calculation fix?
Differential protection setting calculation fixes four numbers for one protection zone: the differential pickup, the bias slope, the harmonic restraint ratio and the trip time. The same four govern 87T, 87G, 87M, 87B and 87L; the starting data changes, not the arithmetic. A differential zone compares current entering against current leaving. Inside is a fault to clear, outside is through-current to ride through, so pickup sets the floor, slope sets the boundary, harmonic restraint blocks magnetising inrush, and the time delay covers the first cycles after energisation. Each calculation starts from rated current on every side of the zone, which is the base for CT ratio selection, vector group compensation and differential current scaling. Two zones of the same type can differ, so each is calculated fresh. Device numbers come from ANSI/IEEE C37.2-2022, relay performance from IEC 60255-1:2022, CT behaviour from IEC 61869-2:2012 and fault levels from IEC 60909-0:2016. Setting review and quotation within 12 hours, MOQ 1, 7-15 working days.
Differential protection setting calculation fixes four numbers for one protection zone: the differential pickup, the bias slope, the harmonic restraint ratio and the trip time. The same four numbers govern a transformer (87T), a generator (87G), a motor (87M), a busbar (87B) and a line (87L).
One zone. Four numbers.
What changes between those objects is the data you start from, not the arithmetic. A differential zone compares the current entering it against the current leaving it. Anything inside is a fault to clear; anything outside is through-current to ride through. Pickup sets the floor, slope sets the boundary, harmonic restraint blocks magnetising inrush, and the time delay covers the first cycles after energisation.
A relay manufacturer’s tool applies that logic with its own curve definitions, so the values below are the ones you hand over for the setting file, not the final relay configuration. Device numbers come from ANSI/IEEE C37.2-2022, relay performance requirements from IEC 60255-1:2022, current transformer behaviour from IEC 61869-2:2012, and fault levels from IEC 60909-0:2016.
Differential Protection Setting Calculation: At a Glance
Eight facts cover most setting work on any differential zone:
- 87T transformer, start from rated power, voltage ratio, vector group, OLTC range and both CT ratios; inrush makes second-harmonic restraint necessary.
- 87G generator, start from rated MVA, power factor and the stator winding arrangement; pickup can sit lower than on a transformer zone.
- 87M motor, start from full-load current, starting current and starting time; the CTs carry a starting transient the pickup must ride through.
- 87B busbar, start from the feeder count and the CT ratios and classes on every feeder; CT saturation on an out-of-zone fault sets slope 2.
- 87L line, start from line length, sequence impedance, charging current and the pilot channel; the same bias logic runs over a communication link.
- Pickup, above the maximum unbalanced current the zone produces through CT error, tap change and saturation.
- Slope, slope 1 covers load and light through-faults, slope 2 covers severe external faults where CTs saturate.
- Harmonic restraint, second harmonic blocks inrush, fifth harmonic blocks over-excitation on transformers and generators.
Worked settings for each object sit on their own pages: differential relay fundamentals, 87T transformer differential protection settings, 87M motor protection settings and 87G generator differential protection settings. This page carries the formulas they share.
What Is Differential Protection Relay Setting Calculation?
Differential protection setting calculation determines the operating thresholds and characteristic parameters of one zone.
Selecting a relay for a live project?
Send the system voltage, CT ratio and tripping scheme. Our engineers confirm the model and reply within 12 hours.
Its core objectives include:
- Ensuring reliable detection of internal transformer faults (such as turn-to-turn faults and phase-to-phase short circuits)
- Maintaining stability and preventing misoperation under abnormal conditions, including external faults, inrush currents, and CT saturation
- Achieving an optimal balance between sensitivity (detecting minor internal faults) and security (preventing false trips)
Proper setting calculation is a critical step in relay coordination studies and protection scheme commissioning.
For the operating principle, see our detailed guide on Working Principle.
Data Required for Differential Protection Relay Setting Calculation
Every differential protection setting calculation starts from the same ten inputs. Fill them in once per zone and the seven steps below follow without guesswork:
| Data | Symbol / Example | Why It Matters |
|---|---|---|
| Transformer Rated Power | S | Rated current calculation |
| HV Rated Voltage | U₁ | HV current calculation |
| LV Rated Voltage | U₂ | LV current calculation |
| Vector Group | YNd11 | Phase compensation |
| Transformer Impedance | Z% | Fault current assessment |
| HV CT Ratio | 400/1A | CT secondary current |
| LV CT Ratio | 1200/1A | CT secondary current |
| CT Class | 5P20 / PX | CT performance |
| CT Secondary Current | 1A / 5A | Relay input |
| System Frequency | 50/60 Hz | Protection configuration |
Differential Protection Settings by Protected Object
The zone changes; the four numbers do not. Pick your starting data from this table before you touch a formula:
| Protected object | Device number | Data you start from | What drives the settings |
|---|---|---|---|
| Transformer | 87T | Rated power, voltage ratio, vector group, OLTC range, both CT ratios | Inrush, tap change, CT ratio mismatch between windings |
| Generator | 87G | Rated MVA, power factor, stator winding arrangement, neutral CT | Low internal fault current, no supply-side inrush inside the zone |
| Motor | 87M | Full-load current, starting current and starting time, cable CTs | Starting transient, CT saturation on the first cycles |
| Busbar | 87B | Feeder count, CT ratios and classes on every feeder | CT saturation on out-of-zone faults, zone switching |
| Line | 87L | Line length, sequence impedance, charging current, pilot channel | Charging current, channel delay, current reversal on parallel circuits |
Two zones of the same object type can still differ, so treat every differential protection setting calculation as a fresh one rather than a copy.
Step 1: Calculate Rated Current on Each Side of the Zone
The first step in differential protection setting calculation is to determine the rated current on every side of the zone: both windings of a transformer, both ends of a generator winding, or every feeder on a busbar. These values are the base reference for CT ratio selection, vector group compensation and differential current scaling.
Formula:
For a three-phase transformer, the rated line current is calculated as:
I=3 ×US
Where:
- I = Rated line current (A)
- S = Transformer apparent power (kVA or MVA)
- U = Line-to-line voltage (kV)
Example:
Consider a 63 MVA transformer with a voltage ratio of 132/33 kV and vector group YNd11.
HV Side Calculation:
IHV =3 ×13263,000
IHV =228.6363,000 ≈275.6 A
LV Side Calculation:
ILV =3 ×3363,000
ILV =57.1663,000 ≈1102.5 A
Result Summary:
| Side | Voltage (kV) | Rated Current (A) |
|---|---|---|
| HV | 132 | 275.6 |
| LV | 33 | 1102.5 |
These rated current values will be used in the next steps for CT ratio selection and setting calculations.
Step 2: Calculate CT Secondary Current
After determining the transformer rated currents on both sides, the next step is to calculate the actual secondary currents seen by the relay, based on the selected CT ratios. These values are essential for verifying that the CT secondary currents fall within the relay’s measurement range and for preparing the subsequent amplitude and phase compensation steps.
Formula:
ICT =CT ratioIprimary ×ICT,rated
Where:
- I_CT = CT secondary current (A)
- I_primary = Primary current (transformer rated current on the relevant side) (A)
- CT ratio = CT primary rating (A)
- I_CT,rated = CT secondary rated current, typically 1A or 5A (A)
Example:
Using the same 63 MVA, 132/33 kV transformer from Step 1:
HV Side:
CT ratio: 400/1A
IHV,sec =400275.6 ×1
IHV,sec =0.689×1≈0.689 A
LV Side:
CT ratio: 1200/1A
ILV,sec =12001102.5 ×1
ILV,sec =0.919×1≈0.919 A
Result Summary:
| Side | CT Ratio | CT Secondary Current (A) |
|---|---|---|
| HV | 400/1A | 0.689 |
| LV | 1200/1A | 0.919 |
Important Note:
The two relay-side currents are not necessarily identical before the relay’s amplitude and phase compensation. This difference arises from the selection of CT ratios, transformer voltage ratio, and vector group configuration. The compensation method employed depends on the specific relay architecture and the project configuration. Some relays perform compensation internally based on user-entered parameters, while others may require external interposing CTs or software-based adjustments. Handle this discrepancy properly, or the relay will not see balanced currents under normal load.
Step 3: Calculate Differential Current
Once the CT secondary currents on both sides have been determined, the differential current can be calculated. However, the differential current is not simply obtained by subtracting the two CT secondary current magnitudes directly.
General Expression:
Idiff =∣I1 −I2 ∣
Where:
- I₁ = Current from one side of the transformer (e.g., HV side), referred to the relay’s reference
- I₂ = Current from the other side (e.g., LV side), referred to the same reference
Critical Requirement:
I₁ and I₂ must first be converted and compensated according to the relay’s defined current reference and the transformer vector group. Direct subtraction of the raw HV and LV CT secondary currents is mathematically incorrect, as these currents may differ in magnitude, phase angle, and reference direction. The relay applies internal algorithms to align both currents to a common reference system before calculating the differential quantity.
Operating Conditions:
Normal Condition
Under normal load or through-fault conditions, the compensated currents from both sides are approximately equal:
I1 ≈I2
As a result, the differential current remains small:
Idiff ≈0
The relay remains stable and does not issue a trip command.
External Fault (Through-Fault)
During an external fault outside the transformer zone, the currents on both sides remain largely balanced in theory. However, CT errors, saturation, or mismatched transient responses may produce a residual differential current. To prevent unwanted tripping under these conditions, the relay employs a restraint characteristic (percentage restraint or biased differential protection) that increases the operating threshold as the through-current increases.
Internal Fault
When a fault occurs within the transformer protection zone (e.g., winding short circuit, core fault, or terminal fault), the balanced current relationship is disrupted. The compensated currents I₁ and I₂ pull apart, causing the differential current to rise sharply:
Idiff ≫0
If the differential current exceeds the relay’s operating characteristic (considering both the pickup value and the restraint quantity), the relay issues a trip command to isolate the transformer.
Summary of Operating States:
| Condition | Differential Current | Relay Response |
|---|---|---|
| Normal | Small (I₁ ≈ I₂) | Stable, no trip |
| External Fault | Residual (restrained by through-current) | Stable, no trip |
| Internal Fault | Large (I₁ ≠ I₂) | Trip if characteristic exceeded |
Step 4: Calculate Restraint or Bias Current
The restraint current (also referred to as bias current or through-current) is used in percentage differential protection to establish the relay’s operating boundary. It represents the magnitude of current flowing through the transformer under normal or external fault conditions and serves as the reference against which the differential current is compared.
Common Formula:
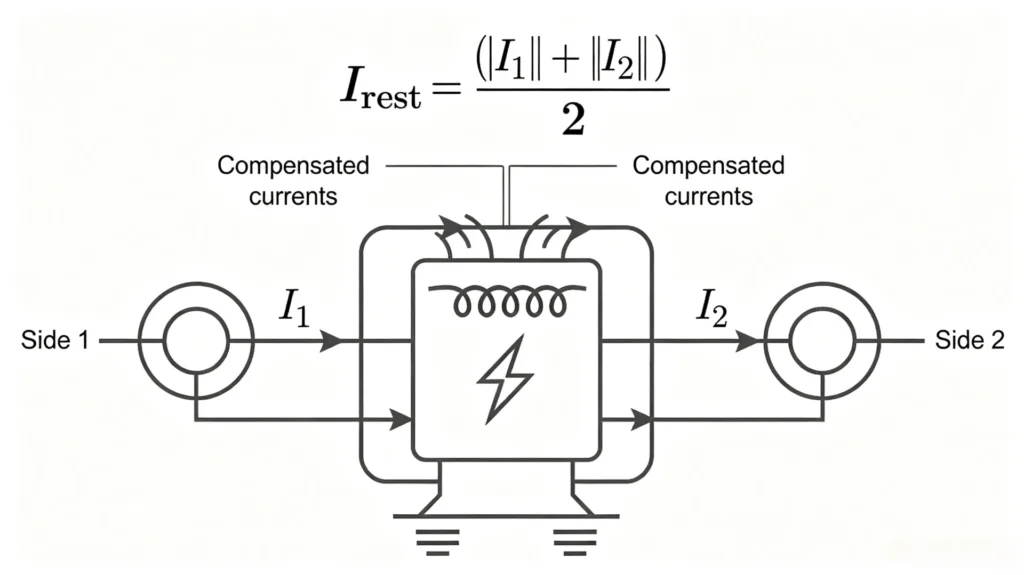
One widely used definition of restraint current is the average of the two compensated currents:
Irest =2∣I1 ∣+∣I2 ∣
Where:
- I₁ = Compensated current from one side (e.g., HV side)
- I₂ = Compensated current from the other side (e.g., LV side)
Other Possible Definitions:
Depending on the relay manufacturer and protection philosophy, alternative restraint current formulas may be used, including:
- Maximum of the two currents: Irest =max(∣I1 ∣,∣I2 ∣)
- Vectorial sum (for certain relay types): Irest =∣I1 +I2 ∣ (under through-fault conditions)
- Weighted sum with different weighting factors for each side
Important Note:
The exact restraint-current definition varies between relay manufacturers. Always use the calculation method specified in the relay manual when converting the calculation into actual settings. Using an incorrect restraint formula during the setting process may lead to either over-sensitivity (risk of false tripping) or under-sensitivity (delayed or failed operation for internal faults).
Purpose of Restraint Current in Protection Characteristic:
Once both the differential current (I_diff) and the restraint current (I_rest) are determined, the relay plots the operating point on its characteristic curve. The relay operates only when:
Idiff >f(Irest )
where f(I_rest) defines the relay’s trip characteristic (typically a dual-slope or single-slope curve with a minimum pickup threshold). This principle ensures stability during high through-fault currents while maintaining sensitivity for low-magnitude internal faults.
Step 5: Bias Slope Calculation (Percentage Restraint)
The bias slope (also known as the percentage restraint slope) defines the relationship between the differential current and the restraint current, establishing the relay’s operating boundary across different fault current levels. Proper slope selection is critical to ensure relay security during external faults and sensitivity for internal faults.
Why Is a Bias Slope Required?
Under ideal conditions, the differential current should be zero for normal load and external faults. However, in practice, several factors can produce a spurious differential current:
- CT ratio error – Mismatch between actual and rated CT ratios due to manufacturing tolerances
- CT saturation – Distorted secondary current waveforms during high-current through-faults, particularly with remnant flux in the CT core
- OLTC variation – Changes in transformer voltage ratio that alter the current balance
- Wiring errors – Incorrect CT polarity, connection faults, or different cable impedances
- Measurement errors – Relay internal measurement inaccuracies, quantisation errors, or signal chain drift
The bias slope ensures that the relay’s operating threshold increases with the through-current level, compensating for these error sources and preventing unwanted tripping under external fault conditions.
Slope Characteristics
Most transformer differential relays employ a dual-slope or multi-slope characteristic to optimise performance across different operating regions.
Slope 1 (Low-Current Region)
Slope 1 applies to the low restraint current region, typically corresponding to normal load or light through-fault conditions. In this region:
- The differential current is primarily affected by steady-state errors such as CT ratio mismatch and tap changer variations
- A lower slope value provides high sensitivity for detecting minor internal faults
- This slope is effective at currents up to approximately 1.0 to 2.0 per unit of transformer rated current
Slope 2 (High-Current Region)
Slope 2 applies to the high restraint current region, typically associated with severe external faults or heavy through-fault conditions. In this region:
- The restraint current climbs fast, and CT saturation becomes the dominant error source
- CT saturation introduces substantial differential current, particularly during the first few cycles of fault
- A higher slope value increases the operating threshold, ensuring relay stability during severe external faults
- This slope typically applies for restraint currents above approximately 2.0 to 3.0 per unit
Calculation Logic
The slope is determined by the maximum differential current expected under the worst-case external fault conditions, divided by the corresponding restraint current:
Slope≥Irest Idiff,max
Where:
- I_diff,max = Maximum expected differential current during an external fault, considering CT errors and saturation
- I_rest = Restraint current at the same fault level
Important Note:
This is a simplified engineering relationship for conceptual understanding. The actual relay characteristic may use different definitions of differential and restraint current, multiple slopes, or piecewise characteristics. Modern numerical relays often implement dual-slope, triple-slope, or even adaptive characteristics with additional features such as:
- Cross-blocking between phases
- CT saturation detection and transient blocking
- Differential current vectorial summation (not simply magnitude)
Typical Setting Ranges (for reference only):
| Slope | Typical Range | Application Region |
|---|---|---|
| Slope 1 | 20–35% | Low-current region (normal load to light through-faults) |
| Slope 2 | 50–80% | High-current region (severe external faults with CT saturation) |
Final Recommendation:
Always refer to the specific relay manufacturer’s manual for the exact slope calculation method, characteristic curve shape, and setting procedure. Different relays implement bias slope characteristics with varying definitions, breakpoints, and special features. Use the manufacturer’s settings calculation software or tool to validate and verify the settings under all possible operating and fault scenarios.
Step 6: Determine Differential Pickup Current
The differential pickup current (Idiff>) is the threshold above which the relay initiates tripping. It is the most fundamental setting, directly determining both sensitivity to internal faults and stability against maloperation.
The Core Challenge
The pickup setting must satisfy two conflicting requirements:
- Sensitivity – Low enough to detect internal faults, including minor turn-to-turn short circuits.
- Stability – High enough to override spurious differential currents caused by CT errors, CT saturation, inrush currents, OLTC variations, and measurement errors.
The Design Constraint
These two requirements define a critical design window:
Ipickup > Iunbalance,max. The pickup has to clear whatever unbalance the zone produces on a through-fault.
The pickup must exceed the maximum differential current expected under non-fault conditions to ensure stability.
Ipickup < Iinternal-fault,min. The pickup has to stay under the smallest internal fault the scheme must catch.
The pickup must be below the minimum differential current for any internal fault to ensure sensitivity.
Practical Range
Typical pickup settings range from 15–40% of transformer rated current:
- Higher values (30–40%) for transformers with wide tap ranges or poorly matched CTs
- Lower values (15–25%) for applications with well-matched CTs and stable conditions
Final Requirement
The final pickup setting must satisfy both stability and sensitivity requirements. Verify the setting through calculation of maximum unbalance current, review of minimum internal fault current, and validation using the relay manufacturer’s tools.
Step 7: Estimate Maximum Unbalanced Current
Under ideal conditions, the differential current during normal operation and external faults should be zero. In practice, however, various error sources produce a residual or spurious differential current. Estimating the maximum expected unbalanced current fixes the minimum pickup threshold and the slope characteristic that keep the zone stable.
Key Error Sources
The following factors contribute to unbalanced current:
- CT ratio error – Manufacturing tolerances and variations in CT accuracy class
- CT excitation characteristics – Differences in magnetizing curves and knee-point voltages
- CT saturation – Distorted secondary currents during high-current through-faults, particularly with DC offset and remnant flux
- OLTC range – Tap changer variations that alter the transformer effective turns ratio
- Transformer ratio tolerance – Nameplate tolerance on the transformer rated voltage ratio
- Relay measurement error – Internal analog input errors, quantisation noise, and calculation precision
- Wiring resistance – Differences in cable impedances and burden on CT secondary circuits
Engineering Approach
A practical estimation is typically based on the CT accuracy class and the maximum anticipated through-fault current:
- For CTs with class 5P or 10P, the maximum composite error is typically specified at the rated accuracy limit factor (ALF). Under through-fault conditions, this error can reach several percent
- Additional allowance must be made for OLTC range (e.g., ±10% or ±15%) and transformer ratio tolerance (±1% to ±2%)
- Relay measurement errors are typically small (less than ±1%) in modern numerical relays
Practical Range
As a general reference for preliminary estimation, the maximum unbalanced current often falls in the range of 5–15% of transformer rated current, depending on CT quality, application requirements, and fault level.
Purpose of This Estimate
Worked Differential Protection Setting Calculation Example: 63 MVA Transformer (87T)
This section walks one zone through all seven steps of a differential protection setting calculation. The data is a 63 MVA transformer, but the workflow is identical for a generator, motor, busbar or line zone: swap the input data and keep the arithmetic. Every value here is indicative. Final settings must be validated with the relay manufacturer’s tool and confirmed by site commissioning tests.
Step 1: Transformer Data
| Parameter | Value |
|---|---|
| Rated Power | 63 MVA |
| HV | 132 kV |
| LV | 33 kV |
| Vector Group | YNd11 |
| Impedance | 10.5% |
| HV CT | 400/1A |
| LV CT | 1200/1A |
| Frequency | 50 Hz |
Step 2: Rated Current
HV side:
IHV =3 ×13263,000 ≈275.6 A
LV side:
ILV =3 ×3363,000 ≈1102.5 A
Step 3: CT Secondary Current
HV side (400/1A CT):
IHV,sec =400275.6 ×1≈0.689 A
LV side (1200/1A CT):
ILV,sec =12001102.5 ×1≈0.919 A
Step 4: Vector Group Compensation
For YNd11, the HV and LV windings sit 30 degrees apart. The relay must align both currents to a common reference before it can subtract them.
Important Note:
Some relays do this in software from the vector group setting. Others need it wired into the CT connections. Follow the relay manual either way.
Step 5: Calculate Compensated Currents
Apply the compensation to both CT secondary currents. The arithmetic is relay-specific; this example assumes internal software compensation.
Step 6: Calculate Idiff (Differential Current)
Once compensated currents I₁ and I₂ are obtained:
Idiff =∣I1 −I2 ∣
Under ideal normal conditions, I₁ ≈ I₂, so Idiff is small.
Step 7: Calculate Irest (Restraint Current)
Using the average-value formula (relay-specific):
Irest = (|I1| + |I2|) / 2, using the compensated currents from every side of the zone.
Note: Different relay manufacturers may use different restraint current definitions.
Step 8: Determine Slope
Slope follows the estimated unbalance current and how the CTs behave on a through-fault.
Slope 1 covers the low-current region. Slope 2 covers the high-current region where CT saturation starts to bite.
Step 9: Determine Pickup
The pickup current must satisfy:
Ipickup > Iunbalance,max. The pickup has to clear whatever unbalance the zone produces on a through-fault.
Ipickup < Iinternal-fault,min. The pickup has to stay under the smallest internal fault the scheme must catch.
The final value is selected within this window, balancing sensitivity and stability.
Step 10: Final Relay Setting Table (Indicative)
Indicative results. Confirm each one with the relay tool before you issue the setting sheet.
| Parameter | Calculated Value (Indicative) | Final Setting (To Be Confirmed) |
|---|---|---|
| Differential Pickup | 0.3 pu | To be confirmed via relay tool |
| Slope 1 | 25% | To be confirmed via relay tool |
| Slope 2 | 60% | To be confirmed via relay tool |
| 2nd Harmonic Restraint | 15% | To be confirmed via relay tool |
| CT Ratio HV | 400/1A | 400/1A |
| CT Ratio LV | 1200/1A | 1200/1A |
Run the Same Calculation on Your Own Transformer
The worked example above uses one transformer. On your own unit the pickup, the slopes and the stability check all move with the CT ratios, the vector group and the fault levels. We put the whole sequence into an Excel worksheet: rated current on both sides, CT mismatch, Is1, both bias slopes and the through fault stability margin. Get the 87 differential setting worksheet.
Differential Stability Check and Common Calculation Errors
A differential stability check closes the differential protection setting calculation. Run the finished numbers against three conditions: the heaviest through-fault the zone will see, the energisation inrush of the object, and the smallest internal fault the scheme has to catch. If pickup and slope survive all three, the zone is stable. These are the errors that normally break it:
| Error | Impact |
|---|---|
| Wrong CT ratio | Incorrect compensated current |
| Wrong vector group | Phase mismatch |
| Wrong CT polarity | Persistent differential current |
| Wrong current base | Incorrect pickup |
| Incorrect slope definition | Stability problems |
| Ignoring OLTC range | Excessive differential current |
Differential Relay Setting Formulas
Six calculations carry a differential protection setting calculation from nameplate to setting file. The first two are pure arithmetic; the last four depend on how your relay defines differential and restraint current, so check those definitions in the manual before you enter numbers:
| Calculation | Formula |
|---|---|
| Transformer Rated Current | I=S/3 U |
| CT Secondary Current | Isec =Iprimary /CT ratio×ICT,rated |
| Differential Current | Idiff = |I1 + I2| as a vector sum, taken after ratio and phase compensation |
| Restraint Current | Irest = (|I1| + |I2|) / 2 on most relays; some use max(|I1|, |I2|) |
| Bias Slope | Slope = Idiff / Irest x 100%, one value per region of the characteristic |
| Pickup | Above maximum expected unbalance and below minimum internal-fault requirement |
Verification After Differential Protection Setting Calculation
After a differential protection setting calculation is finished, systematic verification confirms the settings are correct and the scheme operates as intended. The verification consists of three levels:
Parameter Verification
Confirm that the entered parameters match the calculation results and actual site conditions.
Items to verify:
- CT ratio
- Vector group
- Pickup
- Slope
- Harmonic restraint
Secondary Injection
Apply simulated currents to the relay’s analog inputs using a test set to verify internal measurement, logic, and tripping functions.
Items to verify:
- Pickup
- Slope
- Harmonic restraint
- Trip logic
Stability / Primary Injection
Energize the primary system and inject current through the primary circuit to verify the complete protection scheme from CTs through wiring to the relay.
Items to verify:
- CT circuit
- Polarity
- Wiring
- The whole protection path
Detailed Guide: Transformer Differential Protection Testing
Differential Protection Relays for Each Object
Each object needs a relay that supports the zone you are setting. The transformer differential protection relay covers two- and three-winding transformers with ratio and phase compensation, dual-slope bias and harmonic restraint. The 87G generator relay and the 87M motor differential relay apply the same characteristic to their own objects, and the 87B bus differential relay adds zone switching for every connected feeder. Available functions, communication protocols and voltage ratings vary by model.
FAQ
Q1. What is differential protection relay setting calculation?
It sets the pickup, the bias slopes and the harmonic restraint ratio so the zone clears internal faults and stays stable through external faults, inrush and CT saturation.
Q2. What data is required for differential protection setting calculation?
Required data includes:
- Transformer rated capacity
- Voltage ratio
- Vector group
- CT ratios and connection types on both sides
- Impedance
- OLTC range
- Required protection functions
- Communication protocol
Q3. How do you calculate transformer rated current for differential protection?
For a three-phase transformer:
I=3 ×US
where S is apparent power, and U is line-to-line voltage. This gives the rated line current on each side.
Q4. How do you calculate CT secondary current?
ICT = Iprimary / CT ratio x ICT,rated, with ICT,rated at 1 A or 5 A.
where I_primary is the transformer rated current on that side, CT ratio is the primary rating, and I_CT,rated is typically 1A or 5A.
Q5. How is differential current calculated?
Idiff =∣I1 −I2 ∣
where I₁ and I₂ are the compensated currents from both sides, aligned in magnitude and phase according to the transformer vector group and relay reference.
Q6. What is restraint current in differential protection?
Restraint current (or bias current) is the through-current used to stabilize the relay during external faults. A common definition is:
Irest = (|I1| + |I2|) / 2 on most relays, though some take the larger of the two.
The exact formula varies by relay manufacturer.
Q7. How is differential protection slope calculated?
Slope defines how the operating threshold increases with restraint current:
Slope is Idiff,max over Irest: take the worst-case unbalance on an external fault and divide it by the restraint current at that point.
- Slope 1 applies to the low-current region
- Slope 2 applies to high through-fault currents where CT saturation may occur
Typical ranges are 20–35% for Slope 1 and 50–80% for Slope 2. The actual characteristic varies by relay.
Q8. How do you determine the differential pickup setting?
The pickup must satisfy:
- Ipickup >Iunbalance,max (for stability)
- Ipickup <Iinternal−fault,min (for sensitivity)
Typical values range from 15–40% of transformer rated current.
Q9. Why does CT ratio affect differential protection settings?
CT ratio directly determines the secondary current seen by the relay. An incorrect CT ratio leads to incorrect compensated currents, resulting in persistent differential current, possible maloperation, or failure to detect internal faults.
Q10. How should the calculated settings be verified?
Three levels: confirm the entered parameters against the calculation, inject secondary current to prove pickup, slope and trip logic, then inject on the primary side to prove CT circuits, polarity and wiring.
Conclusion
Differential protection setting calculation comes down to four numbers and one rule: the pickup must sit above the unbalance the zone really produces and below the smallest internal fault it has to catch. Every step on this page exists to pin those two limits down with data instead of guesswork.
Send us the single-line diagram, the CT ratios and classes, the object nameplate and the relay model. We return a completed setting sheet with the pickup, both slopes, the harmonic restraint ratio and the verification tests to run on site.
Related Reading
The eight links below each cover one part of the workflow above: object-specific settings, the operating principle, vector group compensation, and how to prove the settings on site.
- Protection relay setting calculation, the general method across all protection functions
- Differential relay, operating principle and where a differential zone starts and ends
- Transformer differential protection setting, 87T settings worked with transformer data
- 87M protection settings, motor differential and thermal settings
- Generator differential protection settings, 87G settings and stator earth fault
- Differential protection for star-delta transformers, vector group compensation
- Transformer differential protection working principle
- Transformer differential protection testing, how to prove the settings on site
When the relay rated current is not the CT rated current
A differential setting is written in multiples of the relay rated current, so the relay rated current has to match the CT secondary current before any calculation is worth doing. On one project it did not: 5 A CTs, 1 A relay. Every pickup and slope computed on that sheet is a factor of five away from the primary current it was meant to represent, and because the numbers look plausible on paper the error reaches commissioning intact. The first line of a setting calculation should state the CT ratio, the CT secondary rating and the relay input rating. If those three do not agree, the calculation should not start. The plants these schemes were installed in are in the project record.
Field record
Transformer differential settings on our projects span 10-110 kV: Tajikistan (Pakrut and Hamadoni substations, 10-110 kV), Saudi Arabia (Sakaka and Al-Jalamid, 33-110 kV) and Myanmar (35-110 kV mine and industrial substations). The pickup calculation does not change with country – what changes is the CT ratio pair available at each end, which is why the mismatch check in step 3 matters more than the slope setting. The full country list is in the project record.
Sources and Standards
The method above follows published standards. Edition years matter: a slope or pickup practice written against an older edition can disagree with the relay in front of you.
| Source | What it covers | Type | Edition |
|---|---|---|---|
| ANSI/IEEE C37.2-2022 | Device numbers for 87T, 87G, 87M, 87B and 87L zones | Standard | 2022 |
| IEC 60255-1:2022 | General requirements for measuring relays and protection equipment | Standard | 2022 |
| IEC 60255-151:2009 | Overcurrent protection functions used as backup to the zone | Standard | 2009 |
| IEC 61869-2:2012 | Current transformer accuracy classes, knee-point voltage and saturation | Standard | 2012 |
| IEC 60909-0:2016 | Short-circuit current calculation for the fault levels a zone must ride through | Standard | 2016 |
| IEEE C37.91-2008 | Guide for protecting power transformers | Guide | 2008 |
| IEEE C37.110-2007 | Guide for selecting current transformers for relaying | Guide | 2007 |
| IEEE C37.102-2023 | Guide for AC generator protection | Guide | 2023 |
| IEC 61850-8-1:2011+AMD1:2020 | Setting file exchange and station bus communication | Standard | 2011+AMD1:2020 |
For a model recommendation, send the system voltage and the load details to our engineering team.
About Author

Hello, I'm Leon Zhang. I have 15 years of experience in the power relay protection industry with extensive pre-sales and after-sales project experience. Our company specializes in various complete sets of relay protection and automation equipment. I can assist customers in solving all practical on-site project challenges and provide optimal integrated solutions.
Tell Us Your Requirement



High Quality
Stable performance, reliable design, ensuring safe operation for power system protection and grid stability.
Fast Delivery
Timely delivery to support your urgent orders and project schedules efficiently and professionally at any time.
Best Warranty
Professional Warranty: Reliable after-sales support for stable relay protection and long-term customer satisfaction.