
-
Leon Zhang sales consultant
-
Email: zxl635973785@gmail.com
-
Phone/WhatsApp: +86 13655813266
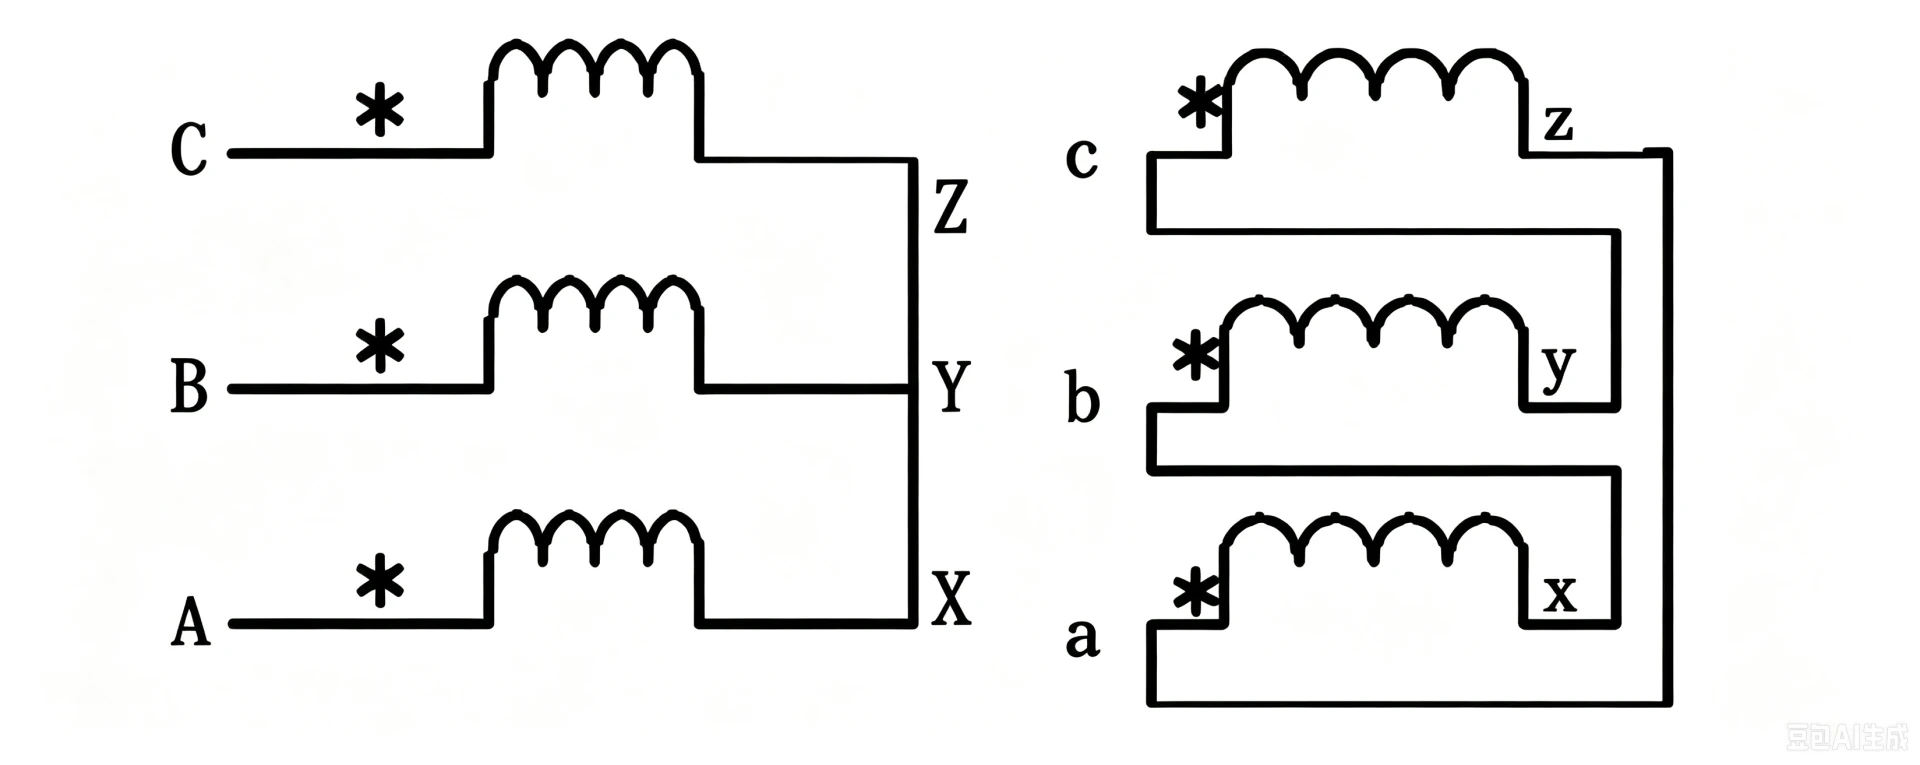
Differential Protection for Star-Delta Transformer: Y-Δ Protection Explained
Introduction
Star-delta (Y-Δ) transformers require particular attention when differential protection is applied because the transformer vector group determines the phase relationship between currents on the two sides of the transformer. The core technical difficulties of star-delta transformer differential protection lie in phase deviation correction and current matching between high-voltage and low-voltage sides.
For a transformer with a Y-Δ connection, the differential relay must correctly account for the transformer ratio, phase displacement, CT polarity and zero-sequence behavior. In traditional protection schemes, CT secondary connections may be used for phase compensation targeting transformer differential protection CT connection specifications. Modern numerical 87T relays can often perform ratio and vector compensation internally, depending on the relay design.
This guide explains the Differential Protection for Star-Delta Transformer, covering vector groups, CT connections, phase compensation, zero-sequence current, and common protection problems involved in differential protection of star-delta transformer engineering applications.
What Is a Star-Delta (Y-Δ) Transformer?
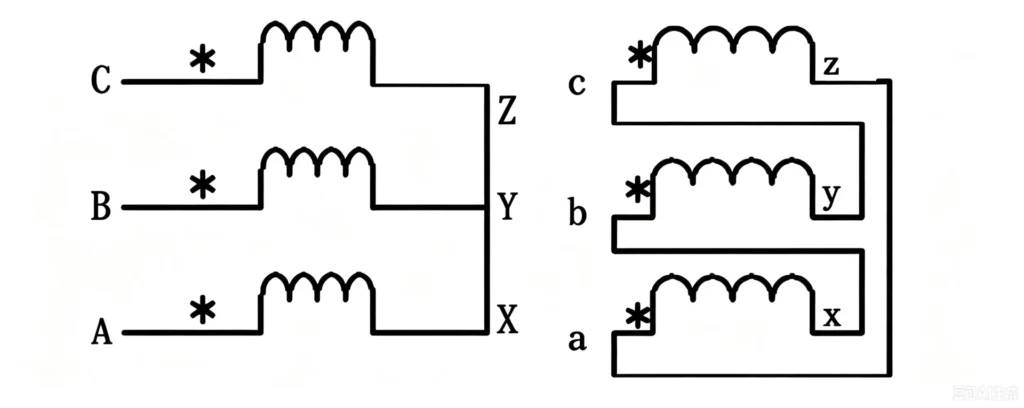
A star-delta (Y-Δ) transformer has the high-voltage (HV) winding connected in star (wye) and the low-voltage (LV) winding connected in delta, which is the most common structural form for Y-delta transformer protection research and application scenarios.
Key Characteristics:
- HV Winding (Star) – Provides a neutral point that can be grounded or left floating, depending on system requirements
- LV Winding (Delta) – Has no accessible neutral point; zero-sequence currents circulate within the delta and do not appear in the line currents
- Phase Displacement – Depends on the vector group (e.g., Yd1 has 30°; Yd11 has 330° or -30°; Yd5 has 150°), which is the main cause of transformer differential protection phase shift
- Vector Group – Defines the phase shift between HV and LV voltages, which must be compensated in differential protection via professional transformer vector group compensation strategies
- Grounding – The star side can be grounded; the delta side is typically ungrounded (no neutral available)
This configuration is widely used in distribution and transmission systems, particularly where the LV side requires a delta connection to trap zero-sequence currents and provide a path for fault current on the star side, supporting stable star delta transformer protection operation.
Transformer Vector Group and Differential Protection
What Is a Transformer Vector Group?
A transformer vector group defines the connection configuration of the transformer windings and the phase displacement between the primary and secondary voltages. It is expressed using a combination of letters and numbers, where:
- Letters indicate the winding connection: D (Delta), Y (Star/Wye), Z (Zigzag)
- Numbers indicate the phase displacement using clock notation (e.g., 1 = 30°, 11 = 330° or -30°)
Example: Yd11 indicates a star-connected HV winding, delta-connected LV winding, with a 330° phase displacement, a typical configuration for Y-delta transformer differential protection.
Why Does Vector Group Matter to Differential Protection?
The vector group determines the phase relationship between currents on the HV and LV sides. For the differential relay to correctly calculate differential current, the currents from both sides must be aligned to a common reference. The relay must compensate for the phase displacement defined by the vector group. Incorrect vector group settings result in persistent differential current, leading to possible misoperation of Y-Δ transformer differential protection equipment.
Dyn11, Yd1, Yd5 and Yd11 – Common Vector Groups
The following table illustrates common vector groups and their winding configurations. Note that the phase displacement varies by vector group and must be determined from the transformer nameplate.
| Vector Group | HV Winding | LV Winding | Phase Displacement |
|---|---|---|---|
| Dyn11 | Delta | Star | Depends on clock notation |
| Yd1 | Star | Delta | Depends on clock notation |
| Yd5 | Star | Delta | Depends on clock notation |
| Yd11 | Star | Delta | Depends on clock notation |
Important Note:
The actual phase displacement must be determined from the transformer’s nameplate vector group rather than assumed from the winding connection alone. For example, a star-delta transformer could be Yd1, Yd5, or Yd11, each with a different phase shift. Always verify the vector group from the transformer nameplate and configure the relay accordingly to ensure reliable Y-Δ transformer differential protection performance.
Phase Displacement in Star-Delta Transformer Differential Protection
A star-delta (Y-Δ) transformer introduces a phase displacement between the corresponding HV and LV voltages and currents. This displacement arises from the winding connections and is determined by the transformer’s vector group. For differential protection to operate correctly, the relay must compensate for this phase shift to align currents from both sides before calculating differential current.
Vector Group and Phase Displacement
The phase displacement is defined by the vector group, which uses clock notation to indicate the angular shift between HV and LV phasors. The actual displacement varies depending on the transformer design and cannot be assumed solely from the winding configuration.
Common Examples
The following examples illustrate how the phase displacement differs across vector groups:
- Dyn11 – HV winding connected in delta, LV winding in star. The LV voltage phasor leads the HV phasor by 330° (or lags by 30°, depending on reference direction). This is one of the most common configurations for distribution transformers.
- Yd1 – HV winding in star, LV winding in delta. The LV voltage phasor lags the HV phasor by 30°. This configuration is often used in transmission systems.
- Yd5 – HV winding in star, LV winding in delta. The LV voltage phasor lags the HV phasor by 150°. This is less common but may be used in specific system applications.
- Yd11 – HV winding in star, LV winding in delta. The LV voltage phasor lags the HV phasor by 330° (or leads by 30°). This is widely used in transmission and industrial applications.
Important Note
The phase displacement is not fixed at a single angle for all star-delta transformers. It varies with the vector group. Always determine the actual phase displacement from the transformer nameplate vector group rather than assuming a standard offset. Incorrect phase compensation will result in persistent differential current and potential relay misoperation.
CT Connections for Star-Delta Transformer Differential Protection
Traditional Differential Protection Schemes
In traditional transformer differential protection schemes, CT secondary connections can be arranged to compensate for the phase displacement introduced by the transformer. For a star-delta transformer, the CTs are typically connected in the opposite configuration to the transformer windings to correct the phase shift. This means:
- If the transformer HV winding is star-connected, the HV CTs may be connected in delta
- If the transformer LV winding is delta-connected, the LV CTs may be connected in star
The exact CT connection depends on the transformer winding configuration and vector group. This approach requires careful CT wiring and is less flexible when changes are needed.
Numerical 87T Relay Schemes
Modern numerical transformer differential relays can perform vector and ratio compensation internally. Therefore, the CT secondary connection should not be selected solely from a generic Y-to-Delta rule; it must follow the relay manufacturer’s wiring diagram and configuration requirements.
In numerical schemes:
- CTs on both sides are typically connected in star (wye) directly to the relay inputs
- Phase compensation is performed internally by the relay software based on the configured vector group
- No external delta connections or interposing CTs are typically required
- Wiring complexity is significantly reduced compared to traditional schemes
Key Difference Summary
| Aspect | Traditional Schemes | Numerical 87T Relays |
|---|---|---|
| CT Connection | Often delta/star combination | Typically star (wye) on both sides |
| Phase Compensation | External (CT connections) | Internal (software) |
| Basis for Connection | Transformer winding configuration | Relay manufacturer’s wiring diagram |
| Flexibility | Limited | High |
Traditional vs Numerical
| Feature | Traditional Scheme | Numerical 87T |
|---|---|---|
| Phase compensation | Often through CT connection | Often internal |
| Ratio compensation | CT / auxiliary CT | Relay configuration |
| Vector group | External wiring consideration | Software configuration |
| CT connection | Scheme-specific | Manufacturer-specific |
| Zero-sequence compensation | Circuit dependent | Configurable depending on relay |
Zero-Sequence Current in Star-Delta Transformer Differential Protection
In a star-delta transformer, zero-sequence current behavior differs between the two windings. Understanding this behavior is essential for correct differential protection application, as zero-sequence currents may appear on one side and not the other, creating an apparent differential current that requires compensation.
Zero-Sequence Current in Star Winding
In a star-connected winding, zero-sequence current can flow when the neutral is grounded. If a ground fault occurs on the star side, zero-sequence current returns through the neutral path and appears in the phase currents on that side. The magnitude and distribution of this current depend on the system grounding arrangement and fault location.
Zero-Sequence Current in Delta Winding
In a delta-connected winding, zero-sequence current cannot flow in the line currents because there is no neutral return path. Instead, zero-sequence currents circulate within the delta winding and do not appear in the external line currents. This means that zero-sequence current present on the star side will not be seen on the delta side line currents.
Effect of Transformer Grounding
The grounding arrangement of the star winding is the primary factor determining zero-sequence current behavior:
| Condition | Zero-Sequence Behavior |
|---|---|
| Star neutral grounded | Zero-sequence can flow on the star side; appears in phase currents |
| Star neutral ungrounded | Zero-sequence cannot flow on the star side (unless provided by external system) |
| Delta side | Zero-sequence does not appear in line currents regardless of grounding (no neutral available) |
Zero-Sequence Compensation in 87T Relays
Numerical 87T relays can compensate for zero-sequence current effects internally. The relay:
- Removes the zero-sequence component from the measured currents before differential calculation
- Applies compensation based on the transformer vector group and neutral grounding configuration
- May offer selectable zero-sequence removal methods depending on the relay model
Compensation ensures that the relay compares only the positive- and negative-sequence components, preventing misoperation during ground faults. The availability and method of zero-sequence compensation depend on the specific relay model and should be configured according to the manufacturer’s instructions.
Important Note:
The behavior of zero-sequence current depends on the winding connection, neutral grounding and transformer construction. Protection schemes must account for this behavior when comparing currents on the two sides. It is not correct to assume that a delta winding simply “blocks” all zero-sequence current in all conditions.
Why Is CT Compensation Required for Y-Δ Transformer Protection?
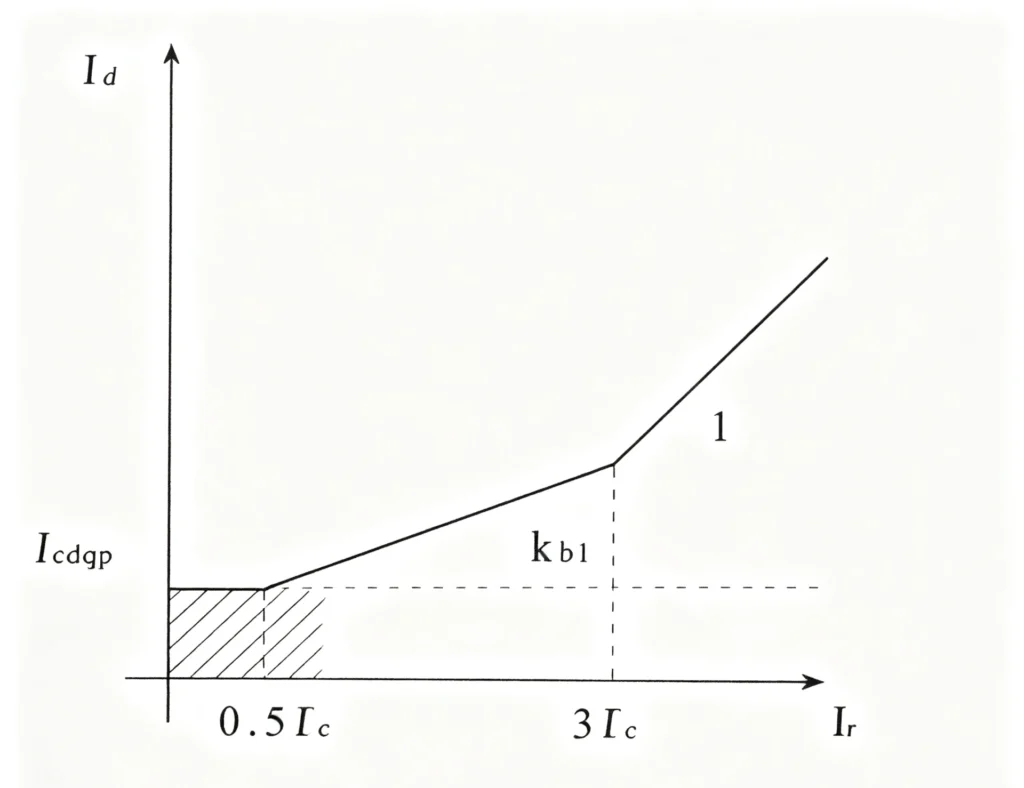
In a star-delta (Y-Δ) transformer, the currents on the HV and LV sides differ in both magnitude and phase. CT compensation is required to ensure that the differential relay compares correctly aligned and scaled currents. Without compensation, the relay would see a persistent differential current even under normal load conditions.
Compensation Workflow
Transformer winding connection (Y/Δ) → Phase displacement introduced by vector group → Different current phase relationship between HV and LV → CT / Relay compensation applied → Correct current comparison achieved → 87T protection decision
Ratio Compensation
The currents on the HV and LV sides differ due to the transformer turns ratio. CT ratios are selected to reduce these currents to measurable secondary values, but the relay must still compensate for the remaining difference. Ratio compensation scales the CT secondary currents to a common base, allowing the relay to compare currents of equivalent magnitude under normal conditions.
Phase Compensation
A star-delta transformer introduces a phase displacement between HV and LV currents, determined by the vector group. The relay must align the currents from both sides to a common phase reference before calculating differential current. Phase compensation corrects this displacement, ensuring that the currents are properly oriented for comparison.
Zero-Sequence Compensation
Zero-sequence current behaves differently on star and delta sides. On the star side, zero-sequence current can flow when the neutral is grounded. On the delta side, zero-sequence current circulates within the winding and does not appear in line currents. Zero-sequence compensation removes this component from the measured currents, preventing it from creating an apparent differential current.
Key Principle
Compensation ensures that the relay compares currents that are correctly scaled, properly aligned in phase, and free from zero-sequence effects. This is essential for reliable differential protection operation and must be correctly configured according to the relay type and application.
Why Is Percentage Bias Still Required for Y-Δ Transformer Protection?
Even after ratio, phase and zero-sequence compensation have been correctly applied, a Y-Δ transformer differential relay still requires percentage-biased differential protection. Compensation alone cannot eliminate all sources of spurious differential current during external faults.
During external faults, high fault currents may cause:
- CT saturation, distorting secondary current waveforms
- CT ratio errors due to manufacturing tolerances
- Small measurement inaccuracies that become significant at high current levels
These effects generate residual differential currents that increase with fault current. A fixed pickup threshold could cause the relay to misinterpret these as internal faults.
Percentage bias addresses this by raising the operating threshold as through-current increases. The relay compares differential current against a threshold that increases with restraint current, ensuring stability during high-current external faults while maintaining sensitivity for internal faults.
Harmonic Restraint in Y-Δ Transformer Differential Protection
Transformer energization produces magnetizing inrush current, creating an apparent differential current that could cause false tripping. Numerical relays use harmonic-based restraint to distinguish inrush from internal faults. During inrush, significant second harmonic content is detected, and the relay applies restraint or blocks tripping. This function applies regardless of winding configuration.
Testing Considerations for Star-Delta Transformer Differential Protection
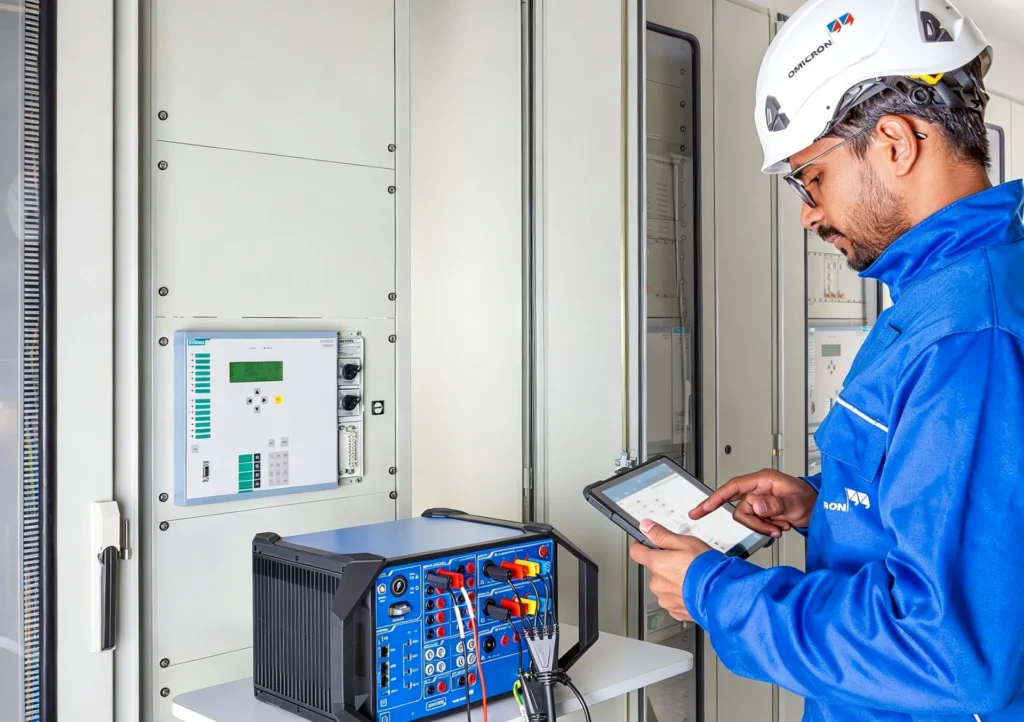
Testing of star-delta (Y-Δ) transformer differential protection should verify all key aspects of the protection scheme to ensure correct operation. The following areas require particular attention:
- CT ratio – Confirm that CT ratios on both sides match nameplate ratings and are correctly entered in the relay
- CT polarity – Verify polarity connections are correct. Polarity errors will cause persistent differential current and possible misoperation
- Vector group – Confirm the relay is configured with the correct vector group from the transformer nameplate
- Phase compensation – Verify that the relay’s phase compensation settings correctly align HV and LV currents
- Differential pickup – Perform secondary injection tests to verify the relay operates at the set pickup threshold
- Slope characteristic – Test the bias characteristic at multiple points to confirm slope settings are correctly implemented
- Harmonic restraint – Verify that harmonic restraint functions correctly during simulated inrush conditions
Testing should include both secondary injection (for verifying relay internal functions) and primary injection (for validating the complete CT-to-relay path) according to site commissioning procedures.
Star-Delta vs Star-Star Transformer Differential Protection
| Feature | Star-Delta | Star-Star |
|---|---|---|
| Winding connection | Y-Δ | Y-Y |
| Phase displacement | Determined by vector group | Determined by vector group |
| CT compensation | Important | Scheme dependent |
| Zero-sequence behavior | Winding/grounding dependent | Winding/grounding dependent |
| Vector group configuration | Critical | Important |
| Numerical relay compensation | Available | Available |
Common Star-Delta Transformer Differential Protection Problems
| Problem | Possible Cause | What to Check |
|---|---|---|
| High differential current during normal load | CT polarity / ratio error | CT wiring and ratio |
| Persistent phase mismatch | Wrong vector group | Transformer nameplate |
| External fault maloperation | CT saturation / incorrect bias | CT and relay characteristic |
| Ground fault instability | Zero-sequence compensation | Grounding and relay configuration |
| Protection does not operate | Incorrect compensation | Relay settings |
| Unexpected trip after energization | Inrush restraint issue | Harmonic restraint |
What to Look for in a Y-Δ Transformer Differential Relay
When selecting a differential relay for a star-delta transformer, consider the following key features:
- Configurable protection logic – Flexibility to adapt protection functions to project requirements
- Vector group compensation – Configurable phase displacement settings to match Yd1, Yd11, Yd5 and other vector groups
- CT ratio compensation – Adjustable ratio compensation to scale HV and LV currents to a common reference
- Percentage bias – Biased differential characteristic for stability during external faults
- Harmonic restraint – Second harmonic blocking or restraint for inrush detection
- Zero-sequence compensation – Configurable zero-sequence removal for star-side ground faults
- Event recording – Fault recording for post-event analysis and troubleshooting
- IEC 61850 – Communication support if required for substation automation integration
Star-Delta Transformer Differential Protection – Q&A
Q1. Why does a star-delta transformer require phase compensation?
A star-delta transformer introduces a phase displacement between HV and LV currents due to the winding connection. Phase compensation aligns the currents from both sides to a common reference, ensuring the relay calculates differential current correctly under normal conditions.
Q2. What is the vector group of a star-delta transformer?
The vector group depends on the transformer design. Common examples include Yd1, Yd5, Yd11, and Dyn11. The actual vector group must be verified from the transformer nameplate and configured accordingly in the relay.
Q3. How does a Dyn11 transformer affect differential protection?
Dyn11 is a specific vector group where the HV winding is delta-connected and the LV winding is star-connected. The relay must be configured for this vector group to apply the correct phase compensation. Incorrect settings will result in persistent differential current.
Q4. What CT connection is used for star-delta transformer differential protection?
The required CT connection depends on the protection scheme and relay type. Traditional schemes may use CT secondary connections to compensate for phase displacement. Numerical relays typically accept star-connected CTs on both sides and perform compensation internally. Always follow the relay manufacturer’s wiring diagram.
Q5. Can a numerical 87T relay compensate for the phase shift internally?
Yes. Most numerical 87T relays can perform phase compensation internally through software settings, based on the configured vector group. This eliminates the need for external CT connection adjustments.
Q6. How does zero-sequence current affect Y-Δ transformer differential protection?
Zero-sequence current can flow on the star side if the neutral is grounded. It does not appear on the delta side line currents. Without compensation, this may create an apparent differential current. Numerical relays can remove zero-sequence internally; traditional schemes may use CT connections to address it.
Q7. Why can incorrect CT polarity cause differential current?
Incorrect CT polarity reverses the phase relationship between primary and secondary currents. This causes currents from both sides to be out of alignment, producing a differential current even under normal load. Polarity must be verified during commissioning.
Q8. What causes false tripping in star-delta transformer differential protection?
Common causes include incorrect vector group settings, CT polarity errors, CT ratio mismatch, zero-sequence current without compensation, CT saturation during external faults, and incorrect harmonic restraint settings.
Q9. What is the difference between Y-Δ and Y-Y transformer differential protection?
The main difference is zero-sequence behavior. Y-Δ transformers have zero-sequence current only on the star side (if grounded), which must be compensated. Y-Y transformers may have zero-sequence on both sides depending on neutral grounding, requiring different compensation considerations.
Q10. How is a star-delta transformer differential relay tested?
Testing includes CT ratio and polarity checks, secondary injection tests for pickup and slope, harmonic restraint verification, and primary injection tests to validate the complete protection path. The vector group and phase compensation settings must also be verified.
Conclusion
Differential protection for star-delta transformers relies on standardized CT connection, accurate vector group compensation, and reasonable parameter setting. The 30° phase shift inherent to Y-Δ structures is the core difficulty of on-site application. Strict compliance with IEC standard schemes and standardized testing & commissioning workflows can completely avoid false tripping and refusal action, ensuring long-term stable operation of power transformers.
For EPC projects and substation construction, selecting high-performance differential relays and professional engineering technical support is the key to improving project quality and reducing later operation and maintenance risks.
About Author
Hello, I'm Leno Zhang. I have 15 years of experience in the power relay protection industry with extensive pre-sales and after-sales project experience. Our company specializes in various complete sets of relay protection and automation equipment. I can assist customers in solving all practical on-site project challenges and provide optimal integrated solutions.
Tell Us Your Requirement
High Quality
Stable performance, reliable design, ensuring safe operation for power system protection and grid stability.
Fast Delivery
Timely delivery to support your urgent orders and project schedules efficiently and professionally at any time.
Best Warranty
Professional Warranty: Reliable after-sales support for stable relay protection and long-term customer satisfaction.